Insights

Research and writing from the projectsim team on simulation and robot evaluation.

  1. 01

    Estimating physics from images: what real measurements reveal

    Read
    Blog post

    We weighed and tested real objects to see how closely physical properties estimated from images (mass, friction, hardness and bounce) match reality. Mass and friction estimates beat simple defaults, though a single friction coefficient per object can't capture contacts that vary by surface.
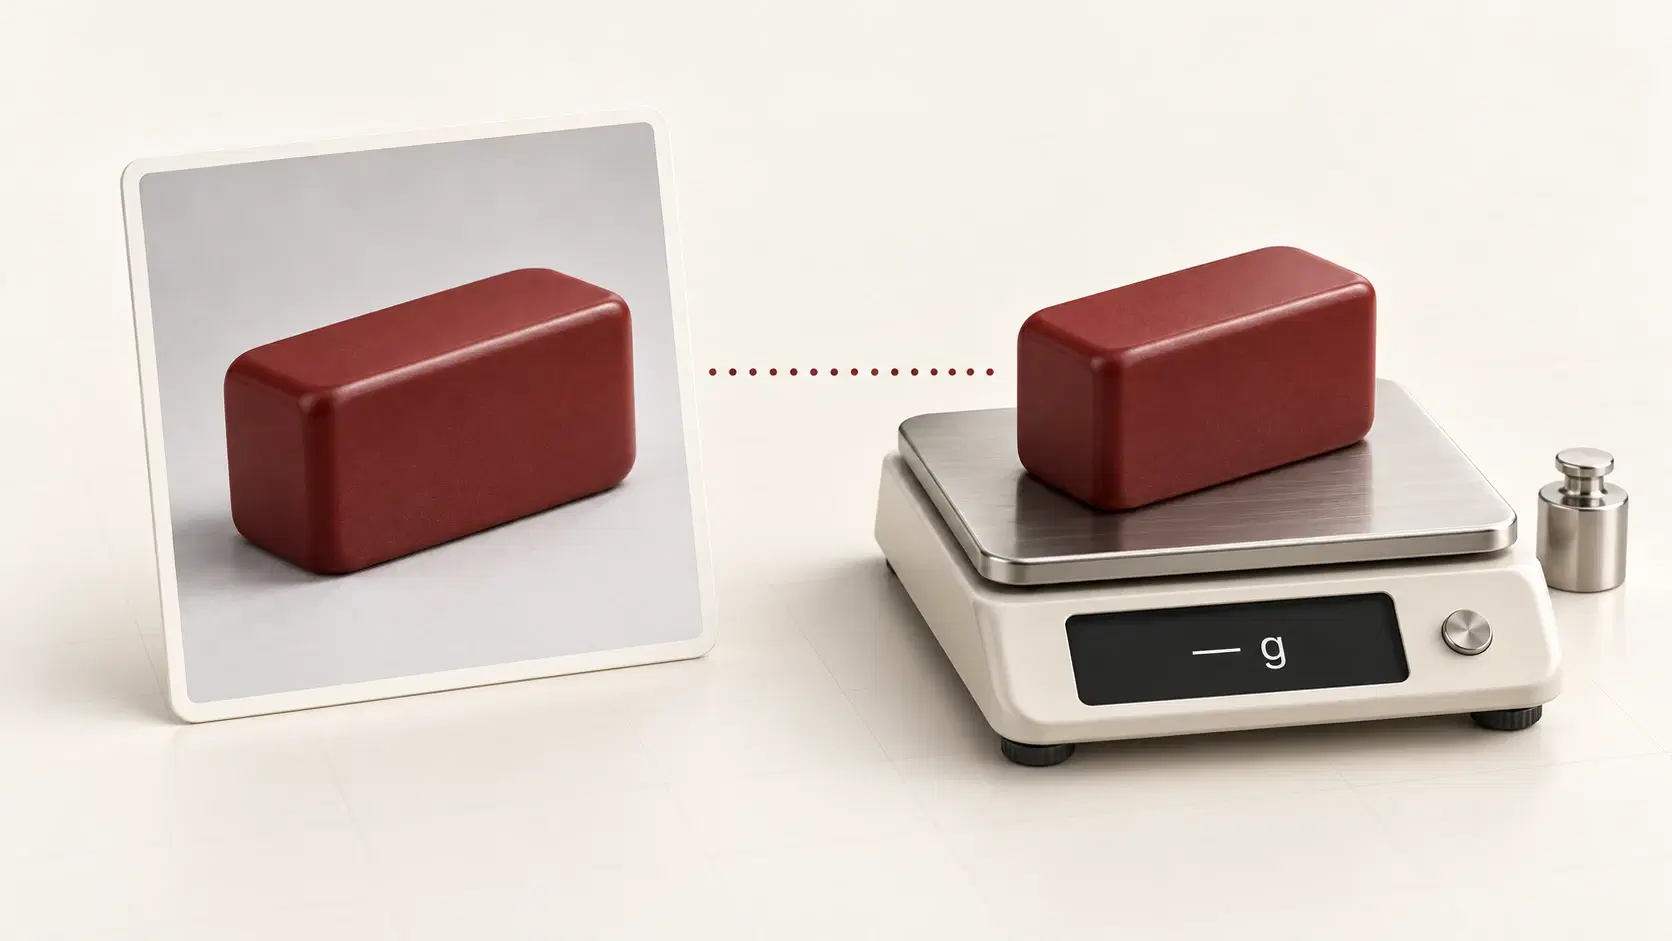
    A photo of a red block beside the same block on a kitchen scale, its weight still unknown
  2. 02

    Measuring Asset and Scene Reconstruction Effects in Real-to-Sim Robot Evaluation

    Paper

    Simulated evaluation is increasingly used alongside real-world evaluation of robot policies because it is cheaper and easier to repeat; however, its value depends on how closely its outcomes track the real robot's. We test whether our reconstruction pipeline, combining metrically scaled object geometry, authored physical parameters and scene reconstruction, reduces disagreement between simulated and real robot scores relative to a default open-source recipe.

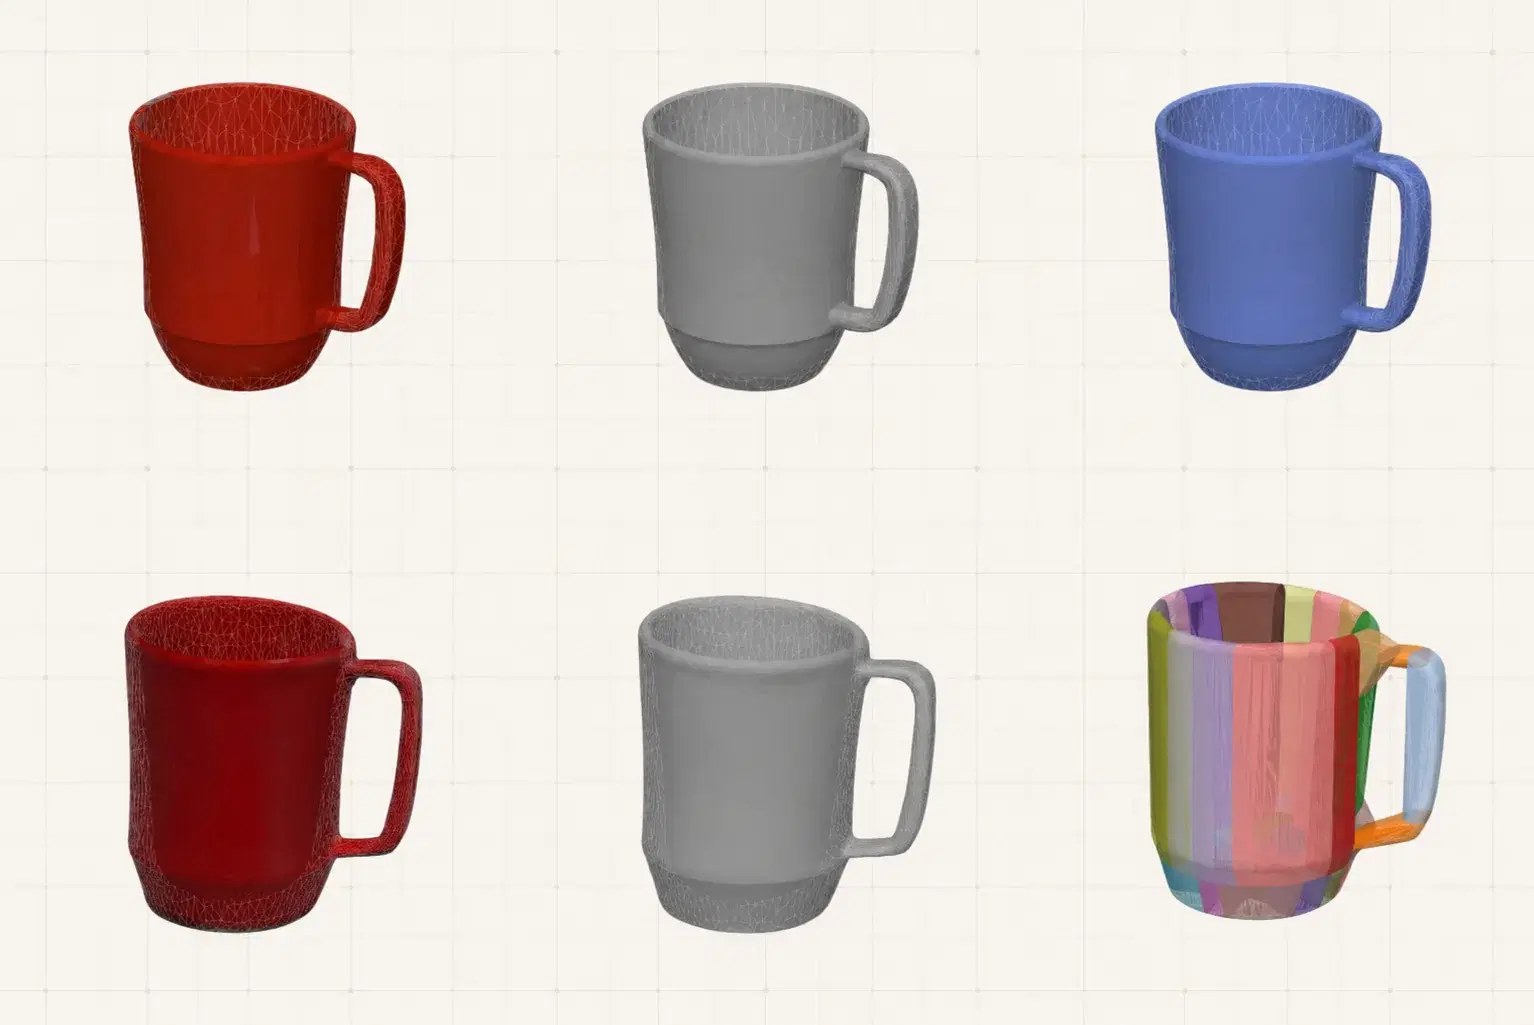
    A mug reconstructed as a sim-ready asset: textured, untextured and wireframe meshes alongside its convex collision decomposition
  3. 03

    Robotics benchmarking: where we are, and what comes next

    Blog post

    A decade after YCB gave grasping research a shared set of objects and protocols, we look at how robotics benchmarks have evolved, where they still fall short, and what simulation-ready assets make possible next.

    Three robot-arm benchmark tasks: placing a cylinder in a target, stacking a cube, and inserting a peg into a hole
Get started

Give your sim meaningful coverage

Start turning images into sim-ready 3D at scale.

Start building