Image in, sim-ready 3D out.
An API that turns images into photorealistic, physics-tested 3D assets—
ready to drop into your existing pipeline.
No pipeline yet? Upload images and download assets directly through the web app.
Complete physical assets, delivered through an API
Send your images and receive sim-ready 3D assets — clean geometry, photorealistic textures, physics tags, and validation built in. Everything you’d otherwise wait weeks for, returned programmatically.
Throughput scales with your call volume, not a vendor's headcount.
Rigid bodies, deformables, and articulated objects (joints, hinges, drawers, tools).
Watertight/manifold status is checked per asset — deterministic. Scale can be grounded to the dimensions you provide.
High-fidelity textures. Sim inputs match what your robot sees in the field.

USD/OpenUSD out
Native in Isaac Sim, Isaac Lab, and Newton (incl. MuJoCo physics via MuJoCo-Warp). Also supported today: MJCF for classic MuJoCo, SDF for Drake, URDF + OBJ, .blend, textured FBX and .uasset for Unreal.
Physics your solver can trust
Dedicated collision geometry
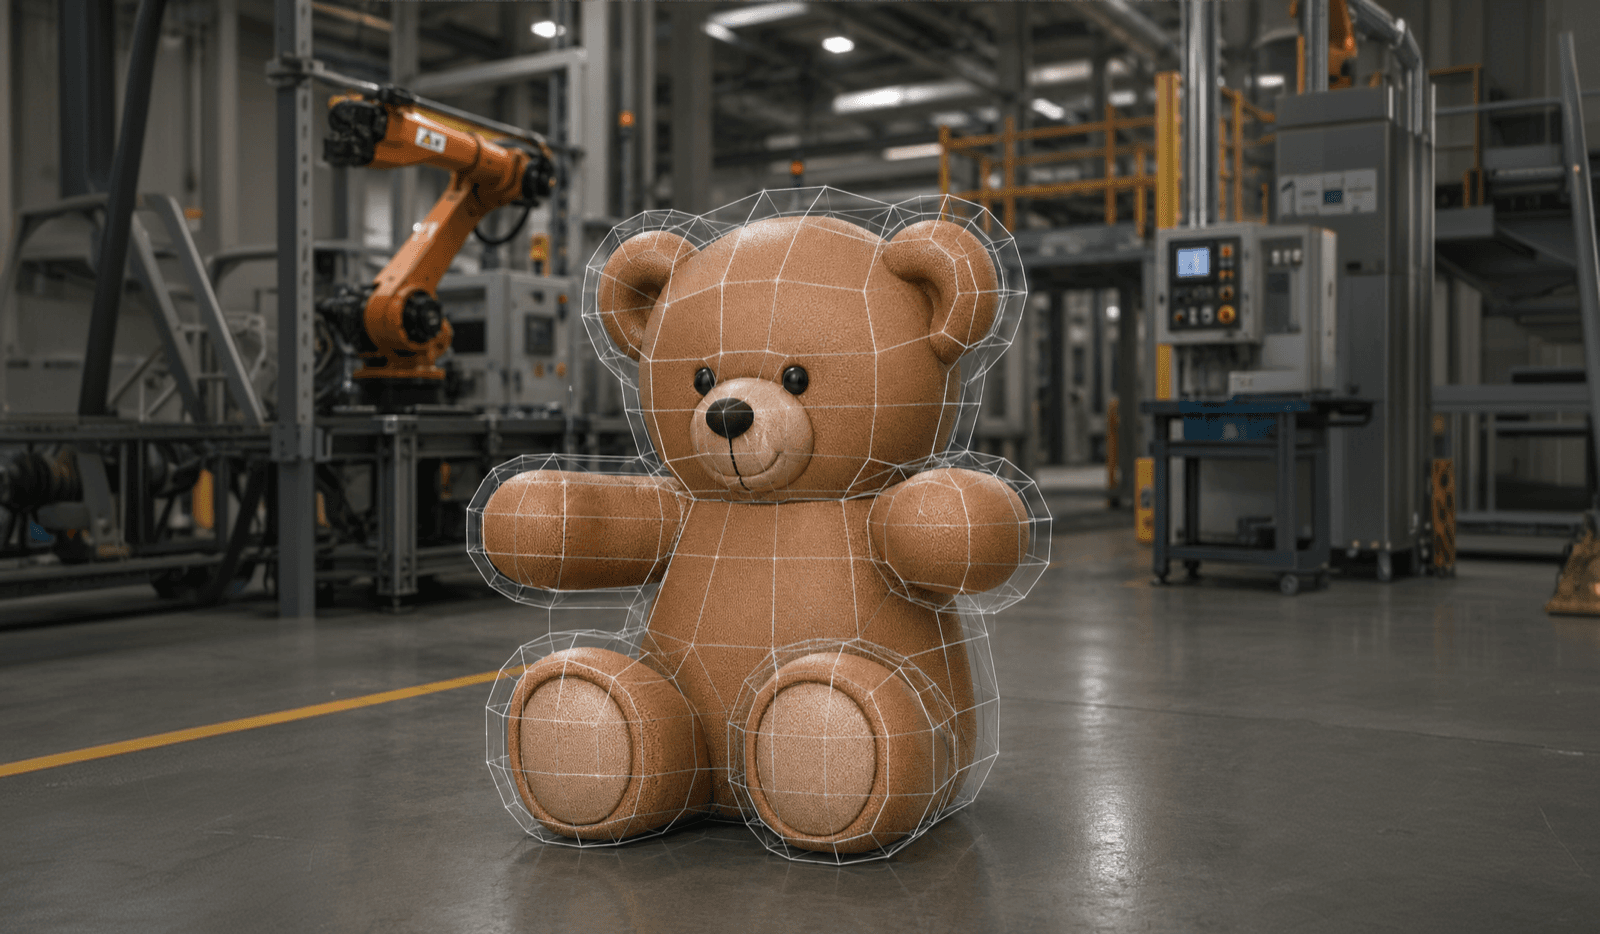
A separate collision mesh accompanies the visual mesh. The default collider is an SDF — true concave contact (a mug is hollow, a shelf has shelves), not a convex-hull shortcut — running on the GPU physics pipeline, with resolution raised automatically if validation measures penetration.
The inertia tensor is derived from the collision geometry and authored mass, assuming uniform density — so it stays consistent with the mass and shape your solver uses.
Built for warehouse and logistics manipulation
Every SKU is a distinct grasp problem, and catalogs grow faster than objects can be scanned by hand. Generate sim-ready assets with validated collision geometry, mass, and friction, giving manipulation policies the full object range to train and test against in simulation.
Send your first image through the API
Start turning images into sim-ready 3D at scale.
Early access